
Seeed Studio reBot Arm B601-RS – 6+1 DoF Open-Source Robotic Arm| 2.5 kg Payload | 754 mm Reach
Technical Specifications
| Specification | Details |
|---|---|
| Model | reBot Arm B601-RS |
| Degrees of Freedom | 6+1 |
| Reach | 754 mm |
| Rated Payload | 2.5 kg |
| Maximum Load | 5 kg |
| Repeatability | ±0.1 mm |
| Weight | 6.5 kg |
| Motors / Servos | ROBSTRIDE 06 × 3 ROBSTRIDE 00 × 4 |
| Joint Range of Motion | J1: ±150° J2: 220° - 0° J3: 220° - 0° J4: ±90° J5: ±90° J6: ±180° Gripper: 345° - 0° |
| Operating Temperature | -20°C to 50°C |
| Power Requirement | 48V 15A (Not Included) |
| ROS1 / ROS2 | Supported |
| MoveIt1 / MoveIt2 | Supported |
| Python | Supported |
| LeRobot | Supported |
| NVIDIA Isaac Sim | Supported |
| Pinocchio | Supported |
| Open Source | Yes |
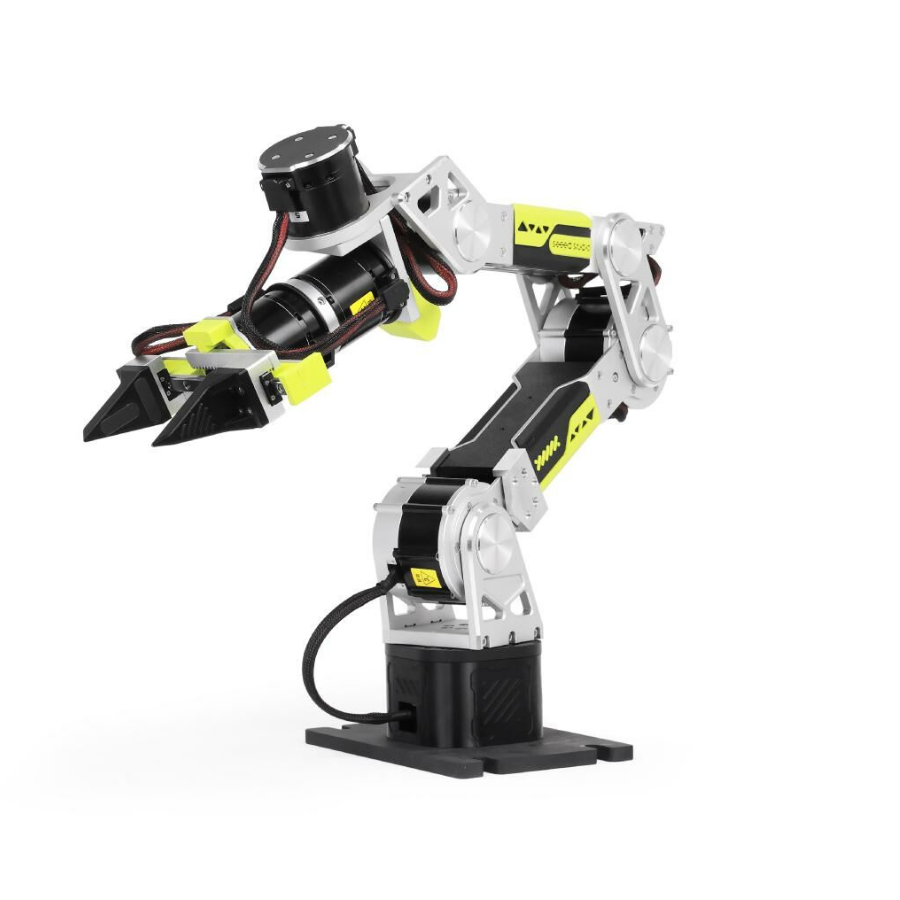
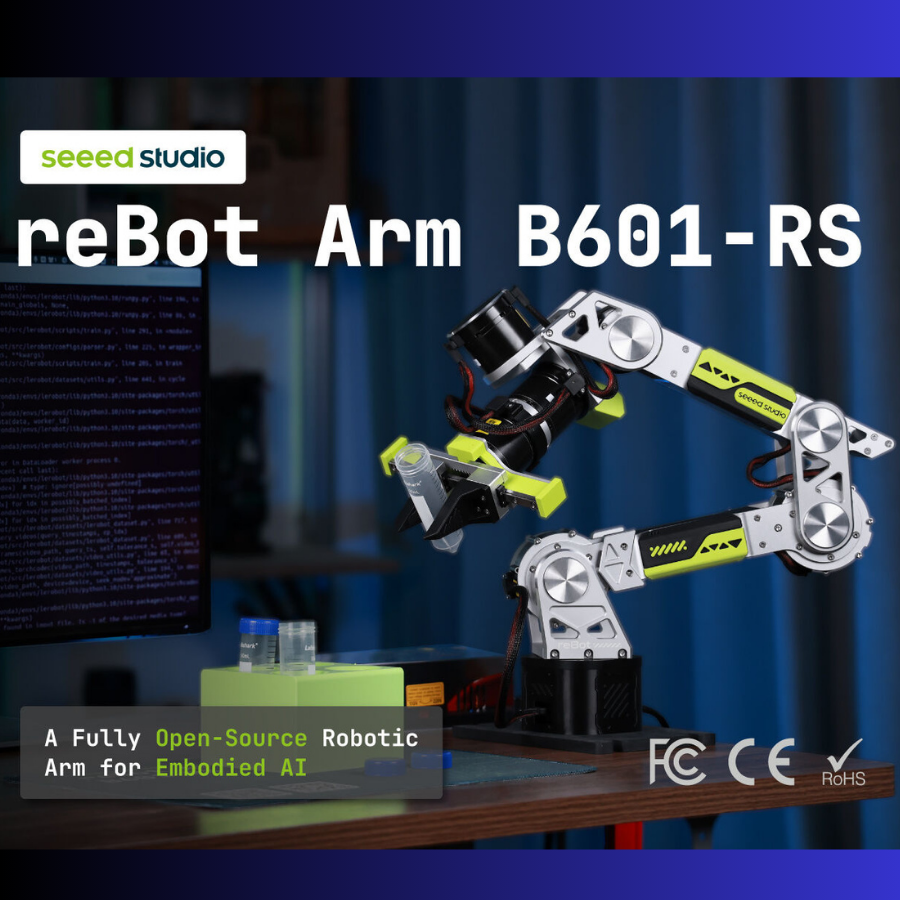
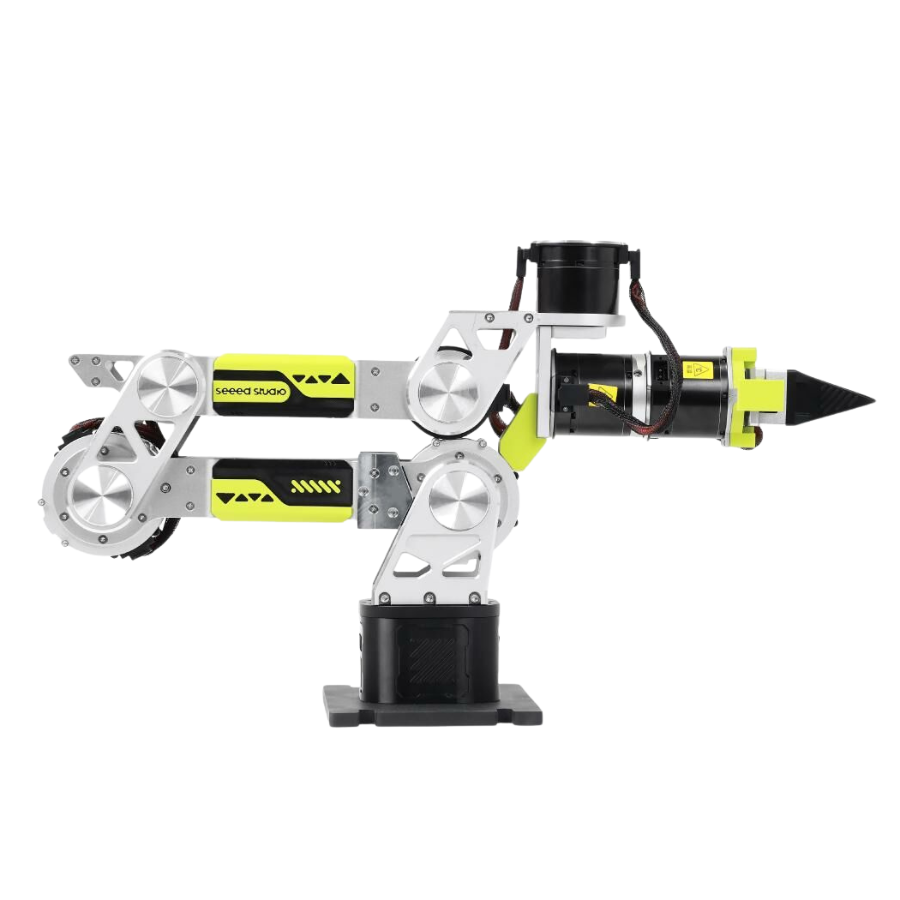
The Seeed Studio reBot Arm B601-RS is a versatile, open-source 6+1 DoF robotic arm engineered for embodied AI development, robotic manipulation, automation, and academic research.
With ±0.1 mm repeatability, 754 mm reach, and a maximum load capacity of 5 kg, this robotic arm provides precise motion control at an accessible price point. Its RobStride Dynamics motors deliver reliable joint actuation for applications ranging from robot learning and teleoperation to laboratory automation and industrial prototyping.
Designed for developers, researchers, universities, and robotics enthusiasts, the B601-RS supports popular development environments, including ROS2, MoveIt2, Hugging Face LeRobot, NVIDIA Isaac Sim, Python, and Pinocchio.
Key Features
-
6+1 Degrees of Freedom: Six robotic arm joints plus an integrated gripper for flexible manipulation and object handling.
-
High-Precision Motion Control: ±0.1 mm repeatability for consistent positioning and repeatable robotic tasks.
-
754 mm Working Reach: Extended workspace for robotic research, pick-and-place operations, and automation experiments.
-
Up to 5 kg Maximum Load: 2.5 kg rated payload and 5 kg maximum load capacity.
-
Fully Open-Source Platform: Access to hardware designs, software, CAD files, SDK, bill of materials (BOM), and algorithms.
-
ROS2 & LeRobot Compatible: Integrate with popular robotics frameworks for robot control, imitation learning, and AI development.
-
Simulation-Ready: Supports NVIDIA Isaac Sim and Pinocchio for simulation and sim-to-real learning.
-
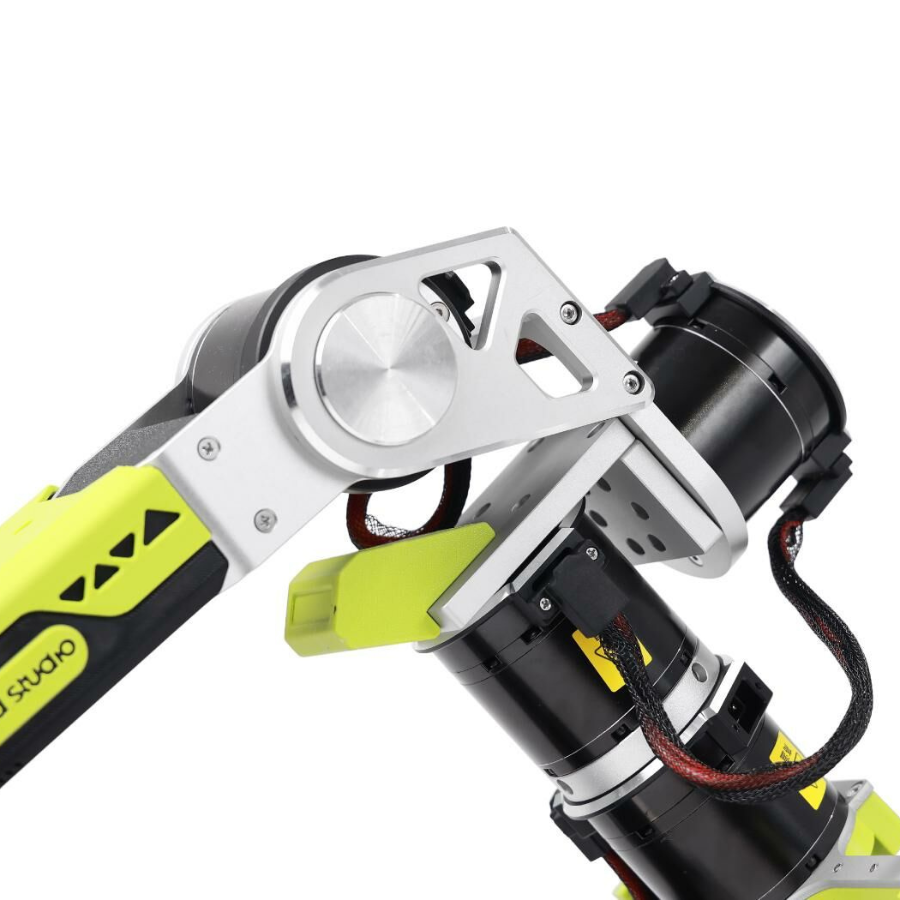
RobStride Dynamics Motors: Equipped with precision robotic actuators for advanced motion control.
-
Developer-Friendly Resources: Tutorials, demonstrations, algorithm updates, and learning materials support robotics development.
Designed for Embodied AI and Robot Learning
The reBot Arm B601-RS provides an accessible hardware platform for developers exploring physical AI, imitation learning, robotic manipulation, and sim-to-real transfer.
Through integration with LeRobot, ROS2, and NVIDIA Isaac Sim, researchers can develop and test robotic control policies, collect manipulation data, and deploy AI-driven behaviors on physical hardware.
The platform also supports teleoperation when paired with a compatible Star Arm 102 leader arm and required power accessories.
Applications
Learn & Build Robotics Easily
Simplify your robotics journey with comprehensive step-by-step tutorials. The reBot Arm B601-RS makes it easy to progress from initial assembly to advanced intelligent robotic control, enabling faster learning and development.

Teleoperation & Data Collection
Pair the B601-RS with a Star Arm 102 leader arm to enable teleoperated robotic control and collect demonstration data for robot learning.

Education & University Research
Explore robot kinematics, ROS2 development, motion planning, and autonomous manipulation using an open-source robotics platform.
Laboratory Automation
Prototype repeatable tasks such as sample transfers, liquid handling, and experimental laboratory workflows.

Industrial Automation & Prototyping
Develop proof-of-concept solutions for pick-and-place, sorting, assembly, inspection, and material handling.

What's Included
-
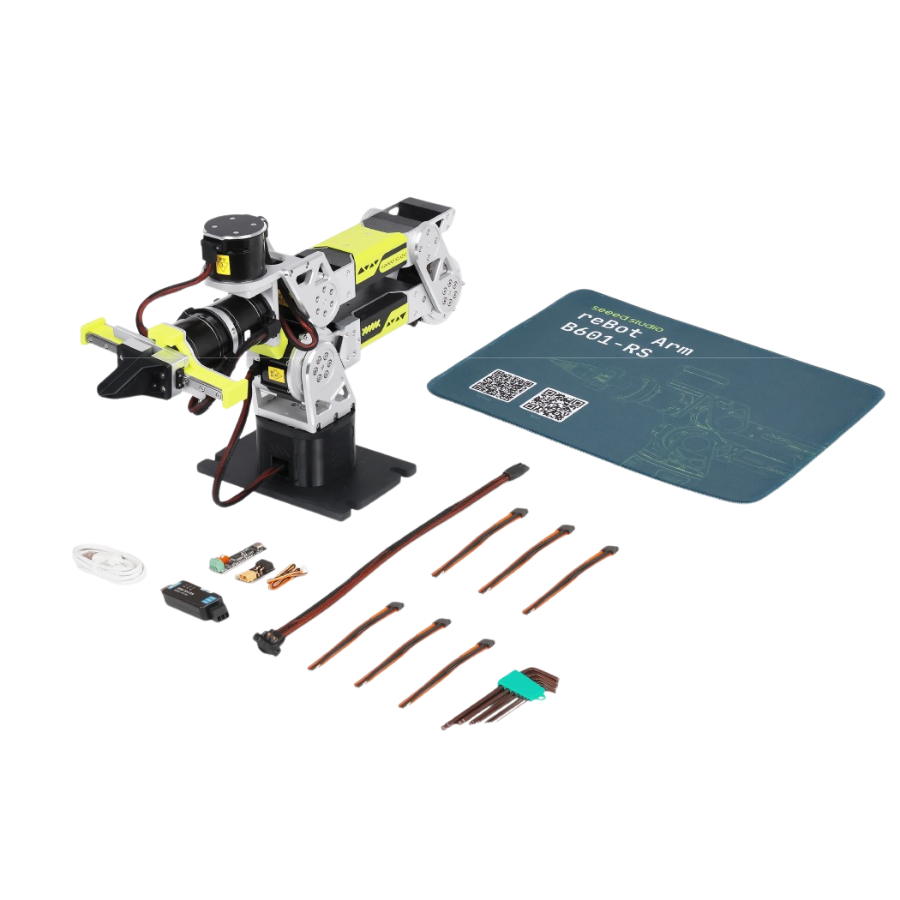
1 × Assembled reBot Arm B601-RS with gripper
-
1 × RobStride USB-CAN Driver Board
-
1 × CANABLE
-
1 × XT30 2+2 Power Separation Board
-
1 × Hex Key Wrench Set
-
1 × Mouse Pad
-
1 × Wire Kit
- Power Adapter
Document: