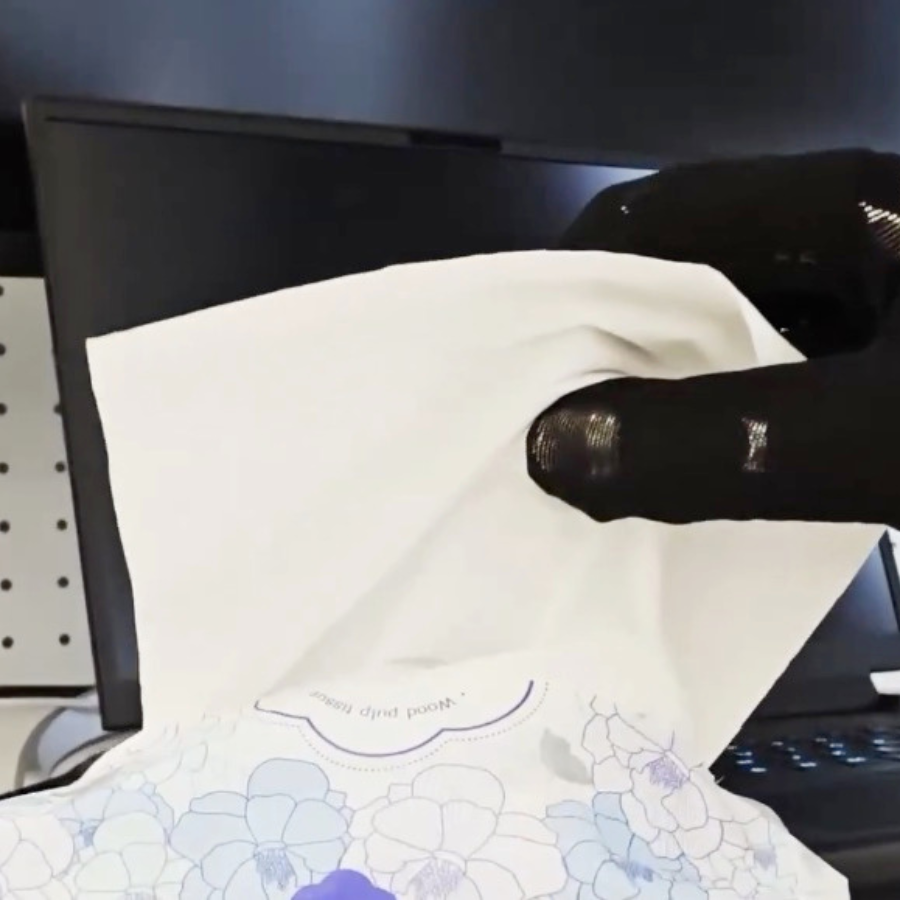

Wuji Glove – Tactile Data Collection & Motion Tracking Glove for Robot Teleoperation
Product Overview
| Core Function | Specification | Output |
|---|---|---|
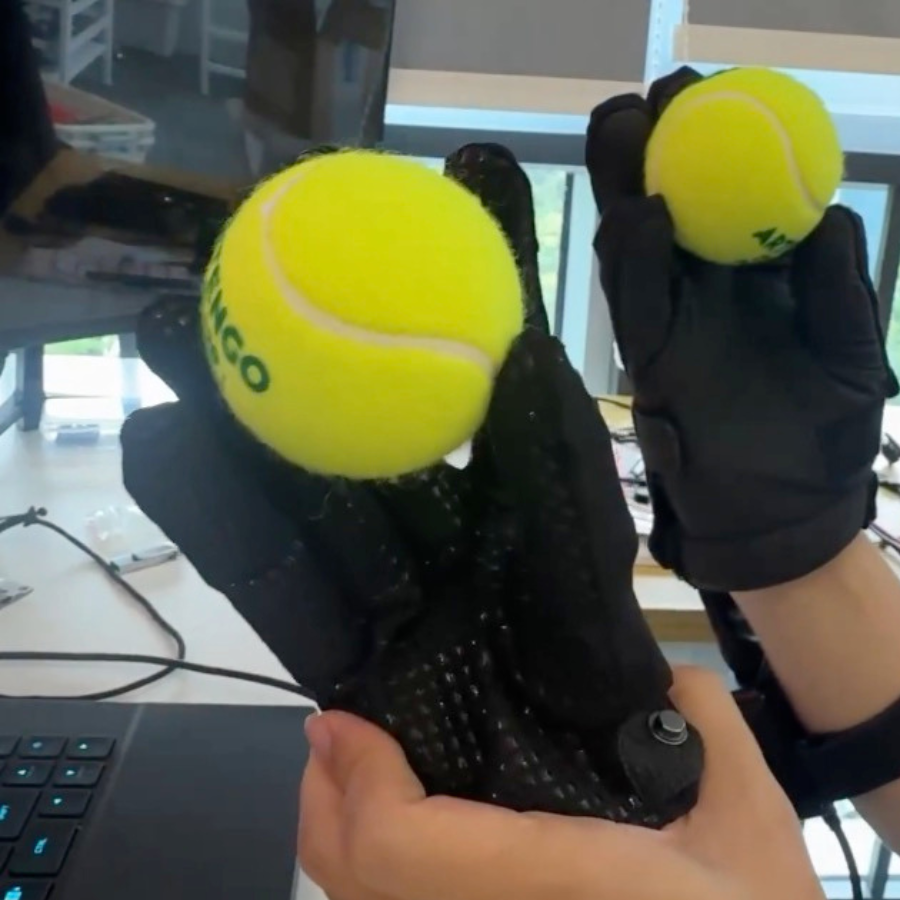
| Tactile Sensing | 24 × 31 pressure sensor matrix with 526 active sensing points | 120 FPS, normalized pressure values from 0–1 |
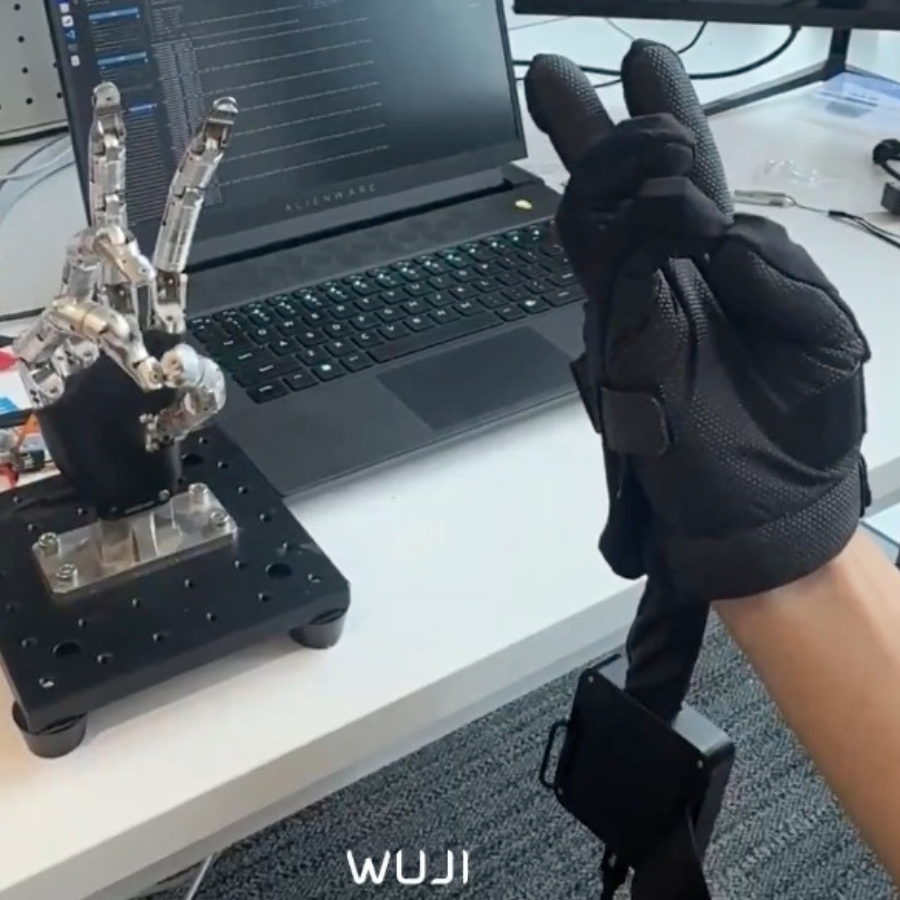
| Pose Tracking | 5 EMF tracking modules | 120 Hz, finger 3D position and pose |
| IMU | 800 Hz high-frequency sampling | Acceleration and angular velocity |
Technical Specifications
Glove Parameters
| Category | Parameter | Specification |
|---|---|---|
| Dimensions & Weight | Glove Size (L × W) | 215 × 195 mm |
| Thickness (Fabric / With Structure) | 6.55 mm / 35 mm | |
| Total Length (With Cable) | 340 mm | |
| Glove Net Weight | 67.5 g | |
| Total Weight (With Cable) | 192.6 g | |
| Tactile Sensor | Sensor Type | Pressure Sensor Matrix |
| Array Resolution | 24 × 31 matrix with 526 active sensing points | |
| Output Rate | 120 FPS | |
| Pressure Range | 0–20 N | |
| Pressure Resolution | 0.1 N | |
| Spatial Resolution | 4 mm | |
| Coverage | Full palmar side | |
| Repeatability | ±6% | |
| Press / Flex Life | 100,000+ cycles | |
| Spatial Tracking | EMF Modules | 5 EMF modules, 6 DoF each |
| Position Accuracy | ≤ 2 mm RMS | |
| Orientation Accuracy | < 5° RMS | |
| IMU | Count / Type | 1 × 6-axis IMU on dorsum |
| Output Rate | 800 Hz | |
| Accelerometer Range | ±16 g | |
| Gyroscope Range | ±2000 °/s | |
| Power & Communication | Power Supply | USB Type-C, 5 V / 1 A |
| Data Interface | RJ45 via adapter, 100BASE-TX | |
| Glove Connector | USB Type-C | |
| Environment | Operating Temperature | -5 to 40 °C |
| Storage Temperature | -10 to 70 °C | |
| Operating Humidity | < 55% RH | |
| Storage Humidity | < 80% RH |
EMF Tracking Specifications
| Category | Parameter | Specification |
|---|---|---|
| EMF Sensor | Output Rate | 120 Hz |
| Motion-to-Data Latency (Wired) | ≤ 10 ms | |
| Hand Kinematics | Sensor Distribution | Thumb, index, middle, ring, and pinky fingertips |
| Sensor Data | 3-axis position + 3-axis rotation | |
| Joint Solving | Real-time inverse kinematics with full-hand joint-angle solving | |
| Position Tracking | External Tracker Mount | External mechanical interface provided |
| Optical Marker Mount | External mechanical interface provided | |
| Environment & Reliability | Interference Resistance | Sensitive to metallic and ferromagnetic materials; maintain at least 3 cm clearance |
| Reliability | No mechanical wear on sensor body; no electromagnetic hysteresis | |
| Calibration | Calibration Steps | 6-step calibration |
| Calibration Goal | Optimized joint-angle accuracy for interaction and gesture recognition | |
| Optimization Targets | Bone length, joint pose, and fingertip pose |
Product Components
| Component | Description |
|---|---|
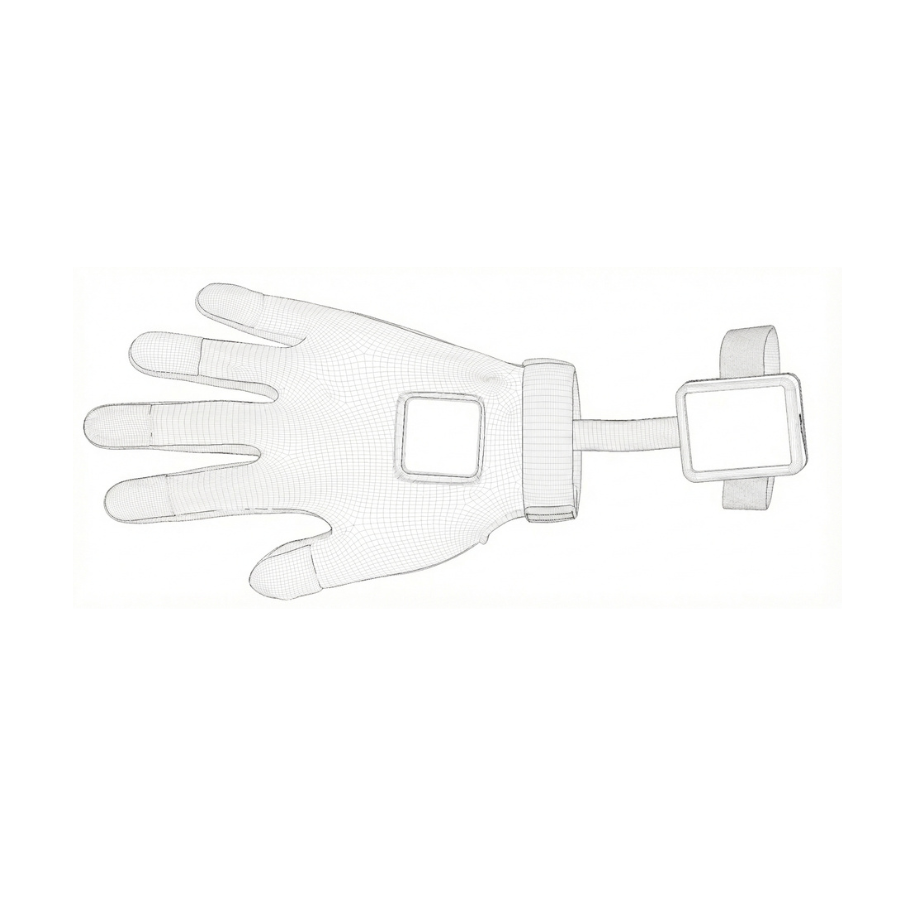
| Glove Palm | High-density tactile sensing array with more than 500 pressure sensing points across the palm. Captures real-time contact pressure and force distribution during object interaction and grasping. |
| Glove Back | Five fingertip EMF modules track hand and finger motion. Combined with hand-kinematics algorithms, the system calculates finger bending, finger spread, fingertip position, and overall hand pose. |
| Data Acquisition Board | Connects the glove sensors and EMF modules to the host system and provides device status indication through the integrated LED. |
LED Status Indicators
| Priority | Color | Pattern | Status |
|---|---|---|---|
| 0 | Off | Off | Power off |
| 15 | Cyan | Breathing, 4-second cycle | Standby; waiting for host connection |
| 20 | Cyan | Heartbeat | Normal operation; data streaming |
| 30 | Green | Fast flash ~50 Hz | Fatal error: no available firmware |
| 35 | Green | Solid | Self-test / hardware initialization |
| 40 | Blue | Fast flash 2 Hz | Firmware update in progress |
| 45 | Yellow | Very slow flash 0.5 Hz | Host connected but not pulling data |
| 50 | Yellow | Slow flash 1 Hz | Non-critical warning |
| 90 | Red | Slow flash 1 Hz | General software error |
| 95 | Red | Fast flash 2 Hz | Ethernet disconnected |
| 100 | Red | Solid | Sensor hardware fault |
Included Accessories
| Accessory | Description |
|---|---|
| USB-C to USB-C Cable | Connects the data acquisition board to the USB-C to Ethernet power adapter. |
| USB-C to Ethernet Power Adapter | Provides glove power and Ethernet communication. |
| USB-A to USB-C Cable | Used with the USB-C to Ethernet power adapter for system connection. |
| Ethernet Cable | Provides wired network communication through the USB-C to Ethernet power adapter. |
Software & SDK
| Item | Wuji Studio | Wuji SDK |
|---|---|---|
| Type | Desktop visualization tool | Python and C SDK |
| Core Capabilities | Multi-device management, data visualization, and firmware upgrades | Real-time tactile data, EMF pose data, IMU streams, and device connection management |
| System Requirements | Ubuntu 22+ | Ubuntu 22+; Python SDK requires Python 3.10+ |